Muslim A. Alaran
PhD Student · Robot Learning · Montanuniversität Leoben, Austria
I am a PhD student and doctoral researcher at the Chair of Cyber-Physical Systems at Montanuniversität Leoben, advised by Prof. Elmar Rückert. I work on skill learning for humanoid robots (Unitree G1, R1), targeting industrial production and logistics tasks.
More broadly, my research lies at the intersection of robot learning, reinforcement learning, and embodied AI, with a focus on dexterous manipulation and generalist robot policies. Before this, I was a junior researcher at the AI for Robotics Lab (FER, University of Zagreb), and I completed my MS in Robotics at Nazarbayev University.
Research Interests
News
Publications
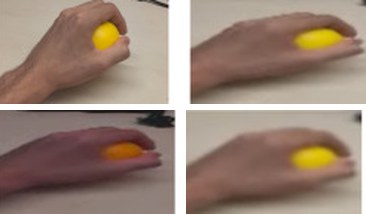
A Time and Object Aware Transformer-Based Method for Structured Hierarchical Gesture Recognition
Robotics and Autonomous Systems, Art. no. 105518, 2026
A hierarchical hand–object gesture recogniser (GCPR) that predicts the primary grasp gesture together with its power, contact type and release behaviour.
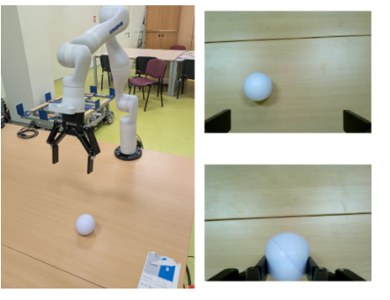
Spatially Aware Value Fusion in Decomposed Reward Architectures for Marine Manipulation
23rd IFAC World Congress, Busan, Republic of Korea, 2026
Adaptively re-weights the value heads of a decomposed-reward RL agent, so it can manipulate under wave-induced motion; validated in simulation and with hardware in the loop on a Kinova Gen3, outperforming existing methods across wave magnitudes.
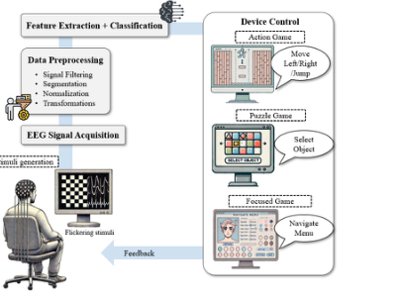
IEEE Access, vol. 13, pp. 74944–74966, 2025
A PRISMA-guided systematic review that screened 16,347 studies down to 46, covering visual-evoked-potential BCIs in gaming: signal acquisition, stimulation paradigms, applications and open challenges.
Challenges and Opportunities of Artificial Intelligence in African Health Space
Digital Health, vol. 11, Art. no. 20552076241305915, 2025
A commentary on where AI can improve diagnosis, disease surveillance and resource allocation in African healthcare, and the privacy, equity, infrastructure and policy barriers it faces.
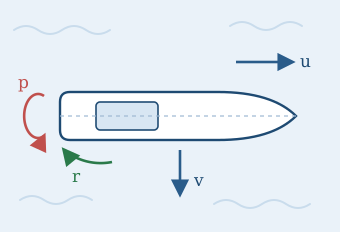
APO-Optimized ARX-Based System Identification of a Ship Maneuvering System
IEEE 22nd International Multi-Conference on Systems, Signals & Devices (SSD), Monastir, Tunisia, 2025
Tunes an ARX model of full 4-DoF ship dynamics with the Artificial Protozoa Optimizer, reaching a mean R² of 0.9437 and improving on existing identification methods.
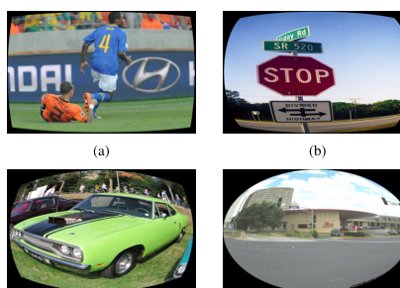
Field of View Invariant Object Recognition Using Non-Linear Transformation Augmentation
IECON 2024, 50th Annual Conference of the IEEE Industrial Electronics Society, Chicago, IL, USA
Builds RMFV365, a 5.1-million-image dataset of perspective images warped into many lens distortions, so that YOLOv7 recognises objects across camera types, from perspective to fisheye.
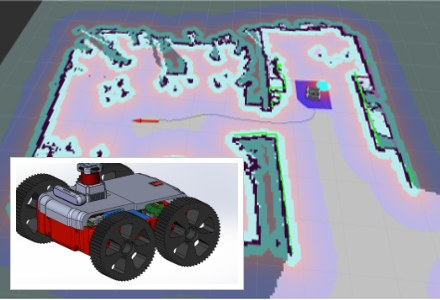
Cloud-Integrated Navigation System for Scalable Autonomous Ground Robots
30th International Conference on Mechatronics and Machine Vision in Practice (M2VIP), Leeds, United Kingdom, 2024
A ROS-based delivery robot that combines A* global planning and DWA obstacle avoidance with AWS cloud services for scalable indoor navigation.
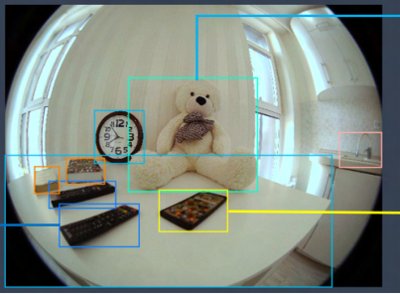
A Data-Centric Approach for Object Recognition in Hemispherical Camera Images
IECON 2023, 49th Annual Conference of the IEEE Industrial Electronics Society, Singapore
Introduces COHI, the first benchmark of real fisheye images (1,000 images, 39 classes); training YOLOv7 on MS COCO combined with its fisheye-transformed version improves accuracy by 2.5%.
Open Source
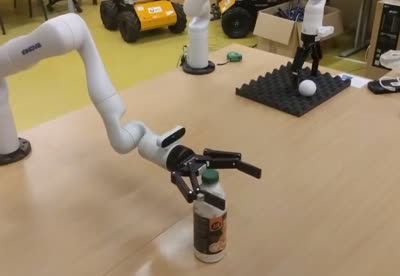
Released pipeline (v1.0.0): demonstration collection, hand-eye calibration, TFDS/RLDS conversion, training, offline evaluation, and live deployment around a latency-aware receding-horizon controller.
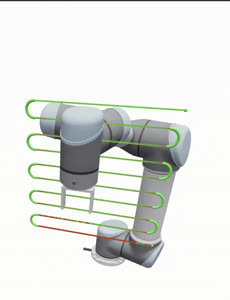
open-planning/roboplan · contributor
Six merged pull requests adding dual end-effector support, a Cartesian trajectory type, acceleration and jerk limits, Jacobian base-frame support, and keyboard teleoperation.
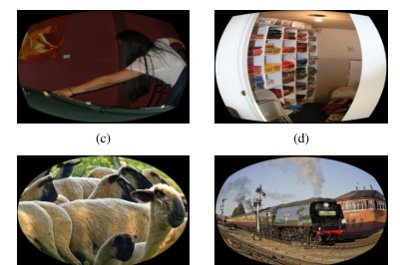
Converts perspective object-detection datasets (COCO, Objects365) into fisheye and wide-FoV training data via eight lens-distortion transforms with matching bounding-box remapping; generalizes the IECON 2024 pipeline into a pip-installable, tested package.
Research Experience
Doctoral Researcher — Chair of Cyber-Physical Systems
Montanuniversität Leoben · Leoben, Austria
- Researching skill learning for humanoid robots (Unitree G1, R1) targeting industrial production and logistics tasks.
Junior Researcher — Artificial Intelligence for Robotics Lab
FER, University of Zagreb · Zagreb, Croatia
- Developed and deployed imitation and reinforcement learning policies for manipulation on Kinova Gen3 arms.
- Owned sim-to-real transfer for a decomposed-reward RL architecture with spatially aware value fusion for marine manipulation.
Research Assistant — Robot Control and Learning Lab
Nazarbayev University · Astana, Kazakhstan
- Built a safety-critical reinforcement learning framework for human–robot collaboration, enforcing Speed and Separation Monitoring constraints in PPO-based motion planning on a 7-DoF Kinova Gen3.
- Prototyped obstacle-avoidance groundwork in MuJoCo, training the arm to reach goals among static and moving obstacles using reward shaping and curriculum learning.
Research Assistant — Institute of Smart Systems and Artificial Intelligence
Nazarbayev University · Astana, Kazakhstan
- Built a 5.1 million-image fisheye dataset using non-linear geometric mapping and trained YOLO models on it for object recognition.
- Generated synthetic training data for object recognition using NVIDIA Omniverse.
- Collected hemispherical-camera images into a 1,000-image fisheye benchmark for evaluation.
Undergraduate Research Assistant
Dept. of Electrical & Electronics Engineering, University of Ilorin · Nigeria
- Reviewed literature and contributed to the design of a multifactor student attendance system using fingerprint biometrics and RFID.
Education
PhD in Robot Learning
Montanuniversität Leoben · Leoben, Austria
Advisor: Prof. Elmar Rückert · Chair of Cyber-Physical Systems
MS in Robotics
Nazarbayev University · Astana, Kazakhstan
GPA 3.7/4.0 · Dean's Honor List (Spring & Fall 2023) · Abay Kunanbayev Scholar
Thesis: Enhanced Object Recognition in Hemispherical Images using Data Augmentation and Synthetic Image Integration
Advisor: Prof. Huseyin Atakan Varol
BEng in Electrical & Electronics Engineering
University of Ilorin · Ilorin, Nigeria
First Class Honors · Top 1% of graduating cohort
Thesis: Attendance Monitoring System using RFID and Fingerprint
Advisor: Dr. I.O.A. Omeiza
Service & Activities
- Reviewer: ICRA 2027, IROS 2025, IECON 2023
- Automation Team Lead, NU Rover, Nazarbayev University · autonomous navigation, object detection, and motion control for the University Rover Challenge2023 – 2024
- Oxford Machine Learning Summer School · representation learning for vision, language, and multi-modal data2024
- Teaching Assistant, Dept. of Robotics, Nazarbayev University · Electrical and Electronic Circuits II; Microcontrollers with Lab2023
Awards & Honors
- Abay Kunanbayev Scholarship, Nazarbayev University · for outstanding international graduate students2022 – 2024
- Award of Appreciation for Excellence in Leadership and Community Building · International Students and Scholars Services, Nazarbayev University2024